Energy-Efficient Control Strategy for Collaborative Robots in Industry 4.0 Environments
Keywords:
Abstract
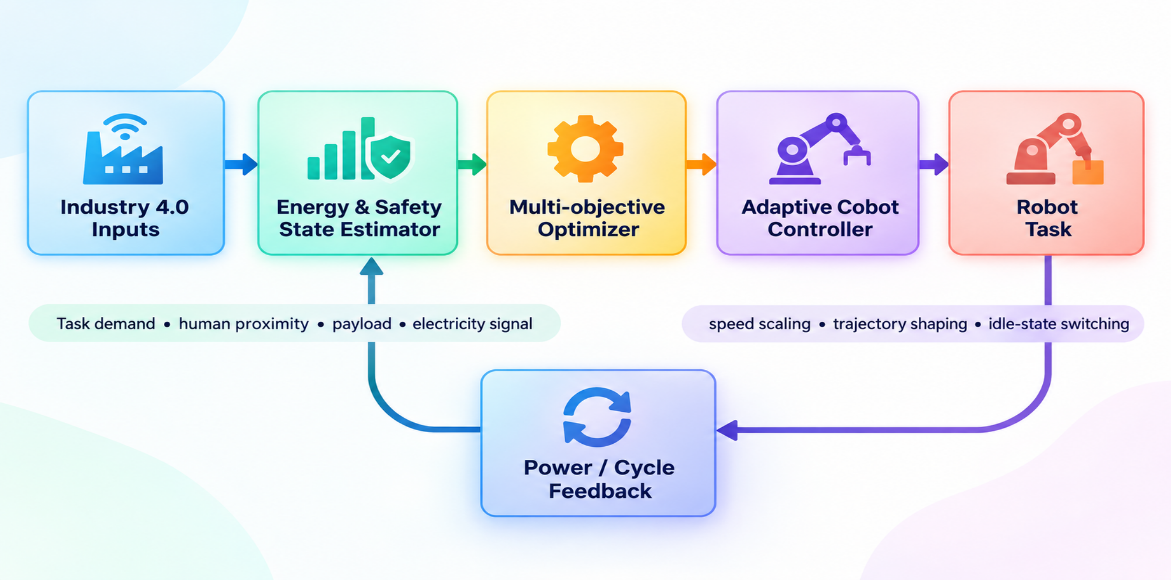
Collaborative robots (cobots) are increasingly deployed in Industry 4.0 production because they provide flexible automation while sharing workspaces with human operators. Their growing use, however, makes electrical energy consumption an important operational and sustainability issue. This paper proposes a methodology for an energy-efficient cobot control strategy that integrates energy-aware trajectory shaping, adaptive speed scaling, idle-state management, and safety constraints within a cyber-physical manufacturing architecture. The controller receives task, payload, human-proximity, cycle-time, and power-feedback information and solves a weighted multi-objective problem that minimizes electrical energy and peak power without violating collaboration safety or production-time limits. A representative six-axis cobot case study is formulated using a joint-level electro-mechanical power model and a discrete supervisory state machine. The methodology compares a conventional fixed-speed controller with energy-aware trajectory control and with the complete proposed strategy. In the representative simulation, the complete strategy reduces cycle energy by approximately 18.6% and peak power by 12.4% while increasing cycle time by only 3.1%. The study shows how energy objectives can be embedded directly into cobot control instead of being treated as a post-process production metric. The proposed framework is suitable for experimental implementation using controller telemetry, smart meters, digital twins, and industrial communication protocols.