Design and Analysis of a Pneumatic Pick-and-Place Robotic Arm for Industrial Material Handling
Keywords:
Abstract
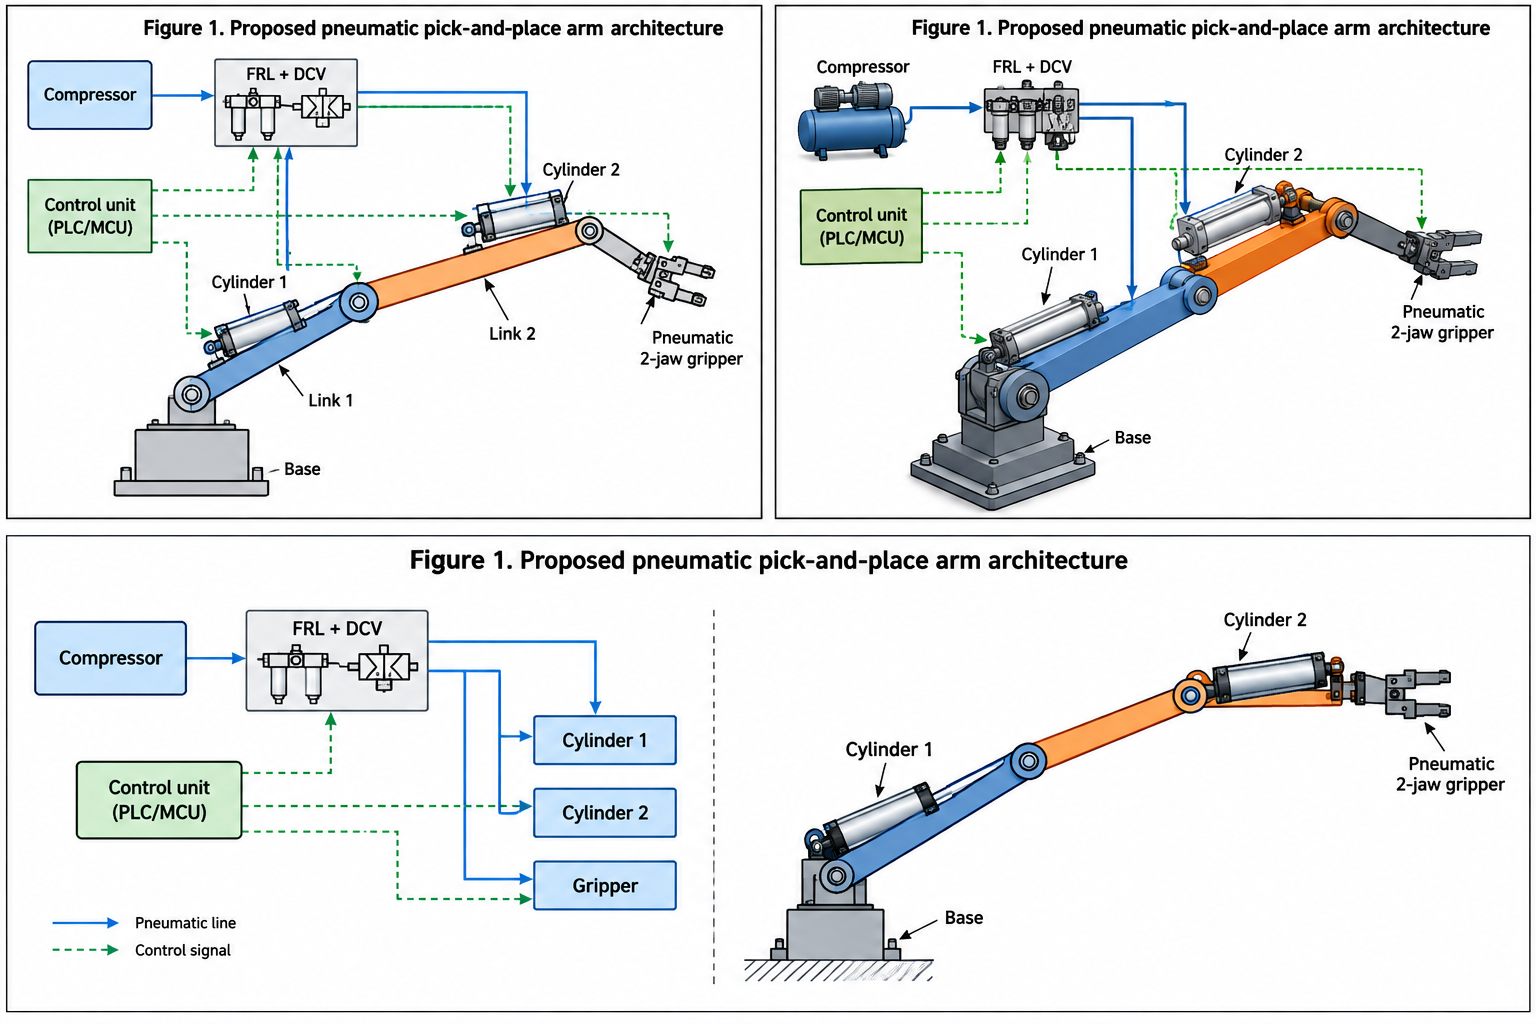
Industrial material handling contains many repetitive pick-and-place operations that require consistent positioning, short cycle times, and safe handling of workpieces. This paper presents a methodology for designing and analysing a compact pneumatic robotic arm intended for repetitive industrial material handling. The proposed system combines a two-joint articulated mechanism, double-acting pneumatic cylinders, a two-jaw pneumatic gripper, a regulated compressed-air supply, directional control valves, and a PLC/microcontroller-based sequence controller. The design procedure begins with task definition and payload selection, followed by workspace sizing, actuator selection, gripper-force calculation, structural load estimation, pneumatic circuit development, and sequence-control design. For a representative design case, a 2 kg payload, 0.6 MPa working pressure, 32 mm cylinder bore, and 0.12 m effective moment arm are used for analytical checks. The calculated cylinder force is approximately 483 N before losses, providing adequate force margin for the selected handling task. Performance is evaluated using payload capacity, grasping reliability, repeatability, cycle time, and pneumatic response. The results presented are design-analysis targets and calculated values rather than measurements from a fabricated prototype. The methodology is intended to provide a practical foundation for a low-cost pneumatic pick-and-place system suitable for repetitive loading, unloading, sorting, and transfer operations.