Design and Fabrication of a Robotic Arm for Pick-and-Place Industrial Applications
Keywords:
Abstract
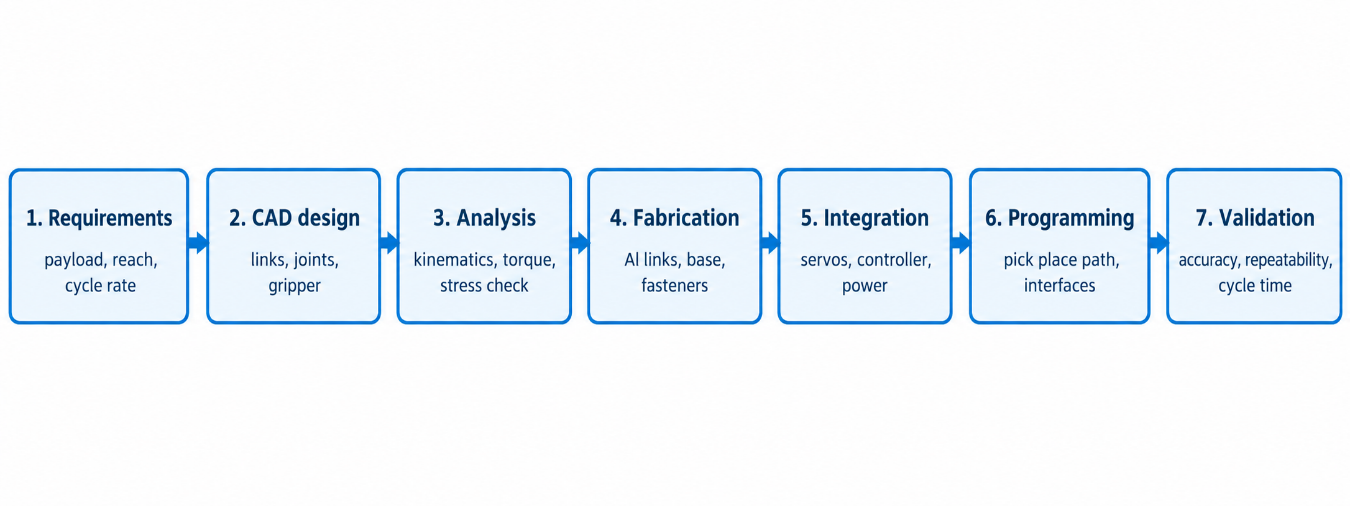
This methodology paper presents a systematic design-and-fabrication framework for a compact articulated robotic arm intended for repetitive pick-and-place operations in small and medium industrial workcells. The proposed architecture uses four controlled rotary joints and a two-finger parallel gripper, with actuator selection based on payload, link mass, static torque, reach, and a safety factor. Mechanical parts are modeled before fabrication, while forward and inverse kinematics define the end-effector position and joint commands. The control sequence is organized around home, approach, grasp, lift, transfer, lower, release, and return states. A low-cost microcontroller and servo-based actuation are adopted to keep the prototype accessible while preserving industrially relevant design principles. The validation plan evaluates reachable workspace, positioning error, repeatability, payload margin, gripper holding capability, and cycle time. Analytical verification for a representative 0.50 kg payload and 450 mm reach indicates that the proposed sizing method can maintain an adequate torque margin at the shoulder joint and can support a repeatable pick-and-place sequence when backlash and structural deflection are controlled. The framework integrates mechanical design, kinematic modeling, actuator sizing, fabrication, programming, and performance verification into a reproducible step-by-step process suitable for laboratory prototyping and future industrial scaling.