Intelligent Path Planning Algorithms for Autonomous Mobile Robots in Dynamic Environments
Keywords:
Abstract
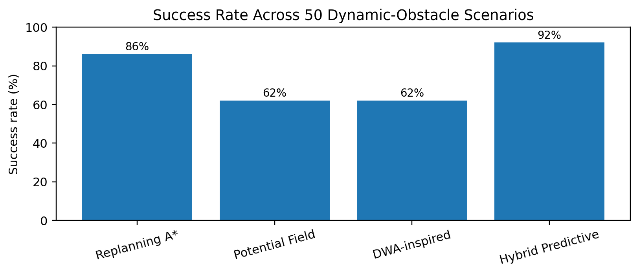
Autonomous mobile robots operating in warehouses, hospitals, campuses, and service environments must plan collision-free motion while the surrounding geometry changes because of pedestrians, vehicles, and other robots. This paper presents a methodology for evaluating intelligent path planning algorithms in dynamic environments and develops a hybrid global-local planning framework that combines graph-based route generation, short-horizon obstacle prediction, and reactive velocity selection. The study considers A* replanning, artificial potential fields, a Dynamic Window Approach (DWA)-inspired local planner, and a predictive hybrid planner. A 30 × 30 occupancy-grid benchmark containing fixed structures and moving obstacles is used to test 50 randomized scenarios under common start-goal conditions. Performance is assessed using success rate, path length, turning events, clearance, and computation time. The results show that the predictive hybrid planner achieves the highest completion rate (92%) while preserving a path length close to repeated A* replanning. Pure potential-field and local DWA-inspired strategies are computationally light but show more failures and longer paths because of local minima or limited global guidance. The methodology demonstrates that intelligent navigation in dynamic environments benefits from combining global optimality information with local motion feasibility and short-term prediction rather than relying on a single planning paradigm.