Design and Development of an Autonomous Mobile Robot for Industrial Material Handling
Keywords:
Abstract
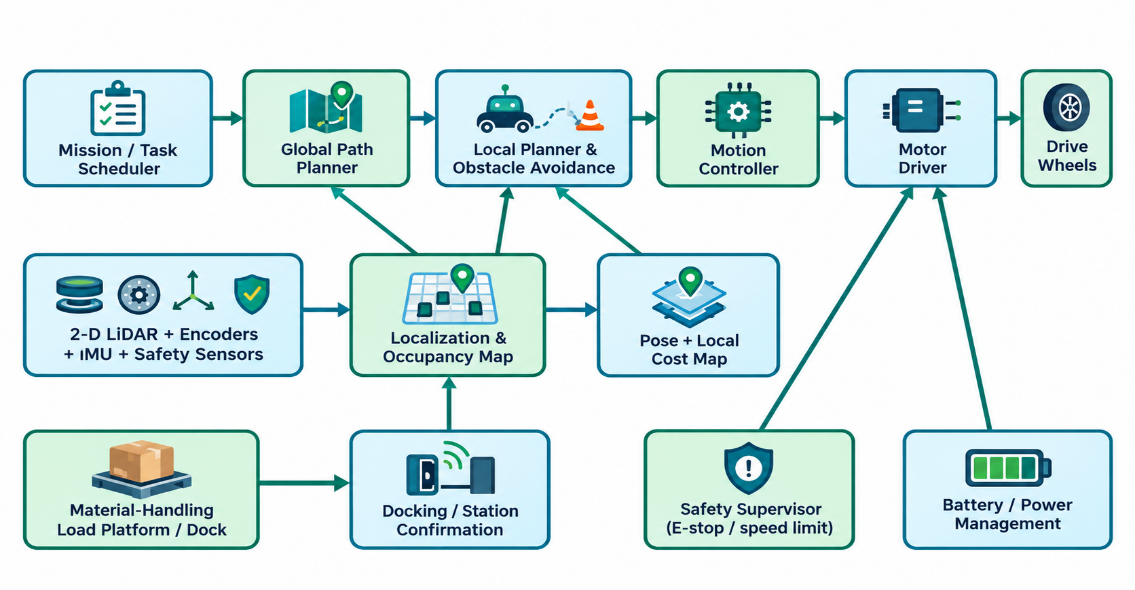
This methodology paper presents the design and development framework of an autonomous mobile robot (AMR) for indoor industrial material handling. The proposed system combines a differential-drive mobile base, a load-carrying platform, 2-D LiDAR, wheel encoders, an inertial measurement unit, short-range safety sensors, an embedded motion controller, and an onboard computer. The navigation architecture is organized into mapping and localization, global path planning, local obstacle avoidance, closed-loop motion control, docking, task execution, and safety supervision. The design intentionally moves beyond fixed-path automated guided vehicles (AGVs) by allowing the robot to localize and re-plan in a changing factory environment while retaining the operational discipline required in material transport. A step-by-step methodology is defined from requirement analysis and mechanical sizing to software integration and validation. Performance is assessed using path-tracking error, localization error, mission completion rate, obstacle-avoidance success, cycle time, path efficiency, and battery-related operating constraints. A simulation-based validation scenario indicates that the proposed architecture can maintain sub-decimeter localization and path-tracking accuracy under representative payloads while preserving a high mission completion rate. The approach is intended as a reproducible foundation for laboratory prototypes and later factory trials, with emphasis on modularity, safety, maintainability, and compatibility with industrial material-flow requirements.